🔬 Research Highlights
DexCanvas [Paper] [Code] [Dataset]
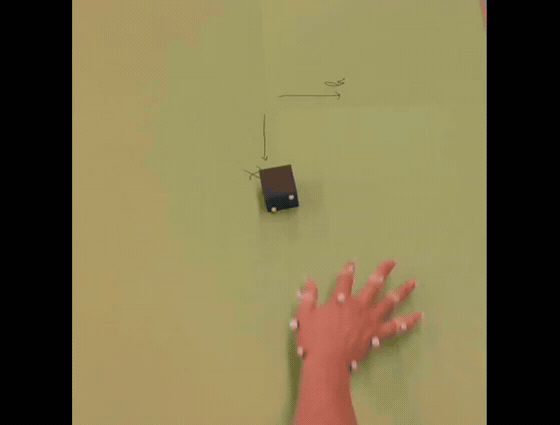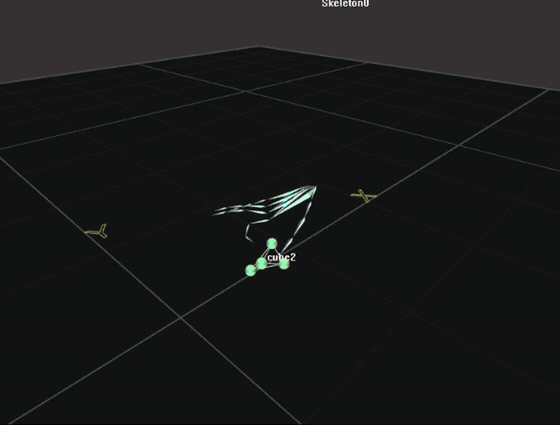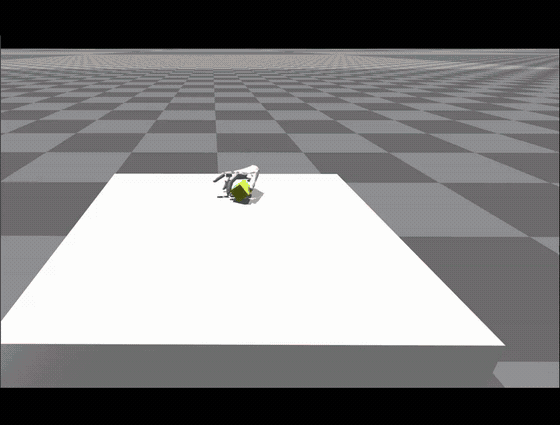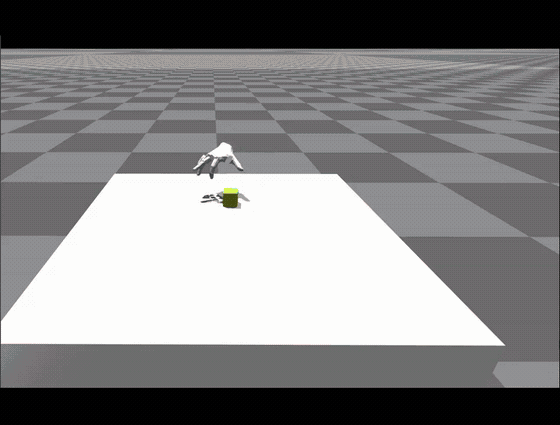
DexCanvas introduces a real-to-simulation framework for reconstructing human hand–object interactions. We organize demonstrations around 21 grasp and in-hand manipulation types based on the Cutkosky taxonomy. Reinforcement learning reproduces these interactions in physics simulation, where we extract physically consistent contact forces and synthesize variations of the demonstrated motions. Combining the original demonstrations with these simulated rollouts yields a dataset of manipulation trajectories and contact annotations for robot learning.
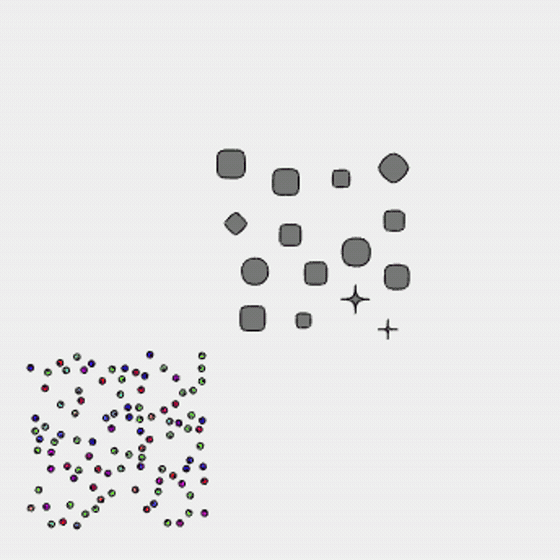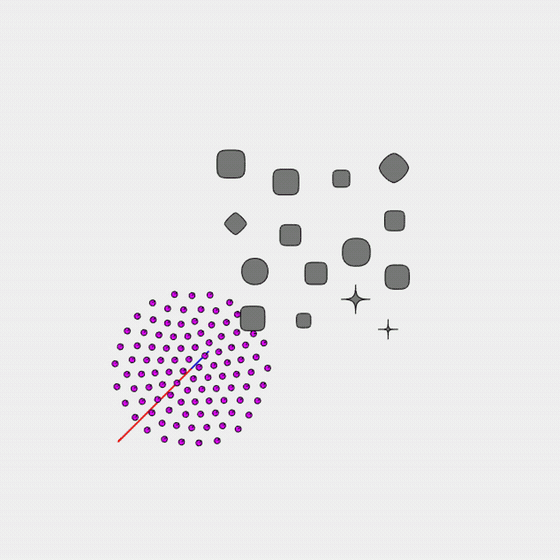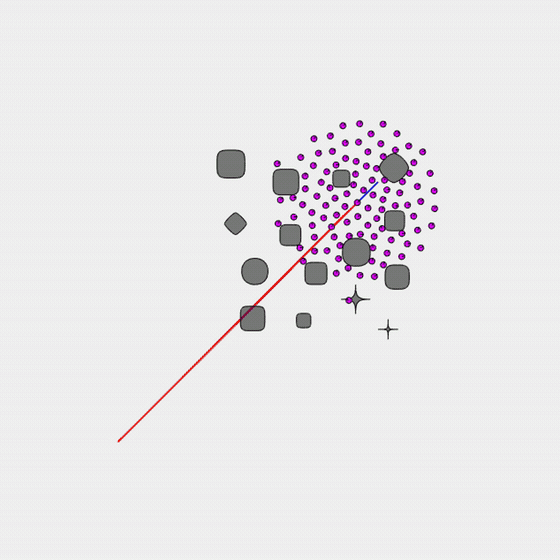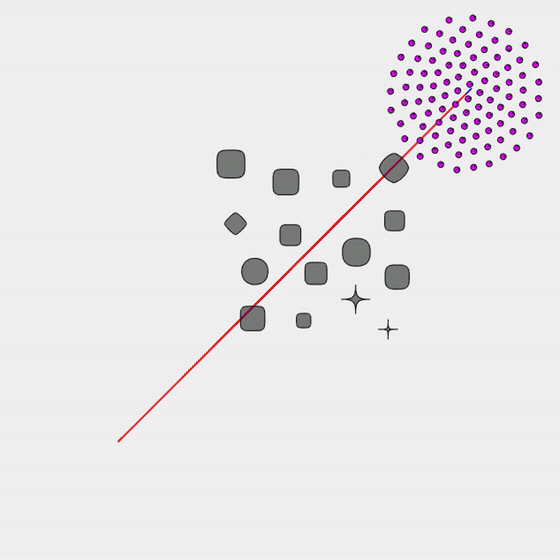
Navigation of Robotic Swarmalators [Paper] [Code] [Video]
We adapt the swarmalator model to robots with omnidirectional, unicycle, and bicycle dynamics, examining how motion constraints reshape collective behavior. Combining swarmalator planning with control barrier functions enables global and per-agent control for navigation through cluttered environments and object transport around obstacles.
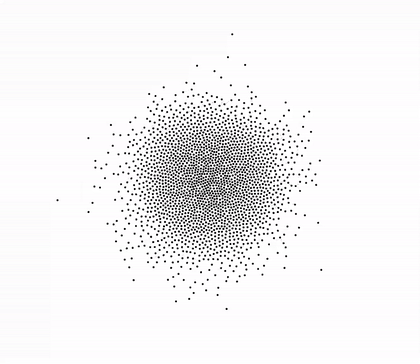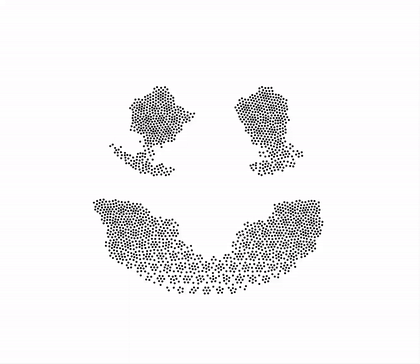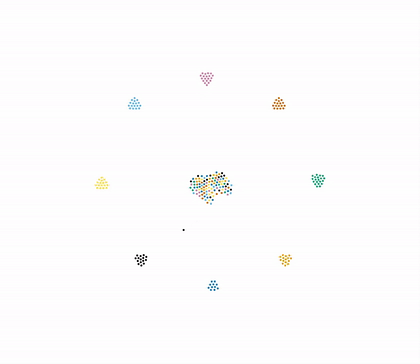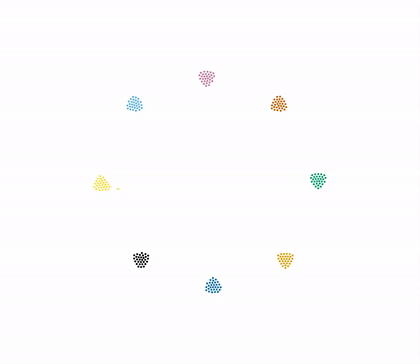
MagFlow [Paper: Under review]
MagFlow controls collectives of passive magnetic millirobots through a shared electromagnetic field. Using camera-based density feedback, optimal transport guides the swarm toward target shapes, while a constrained control allocator converts the desired motion into feasible electromagnet commands. The system enables reset-free shape reconfiguration and separation of multiple groups. These capabilities are verified in both simulation and hardware experiments.
📄 Publications
* Equal contribution.
2026
Nonreciprocal Swarmalators With Reconfigurable and Controllable Formations for Robot Collectives
Kush Patel*, Xinyue Xu*, Wei Xiao, and Steven Ceron.
Advanced Robotics Research, e70161, 2026.
Paper
3D Robotic Swarmalators That Reconfigure, Navigate, and Avoid Obstacles
Zehui Xu*, Xinyue Xu*, and Steven Ceron.
IEEE International Conference on Robotics and Automation (ICRA), 2026.
Paper
Navigation of Robotic Swarmalators With Dynamics and Constraints
Xinyue Xu, Wei Xiao, and Steven Ceron.
IEEE Robotics and Automation Letters (RA-L), 11(2), 1066–1073, 2026.
Paper