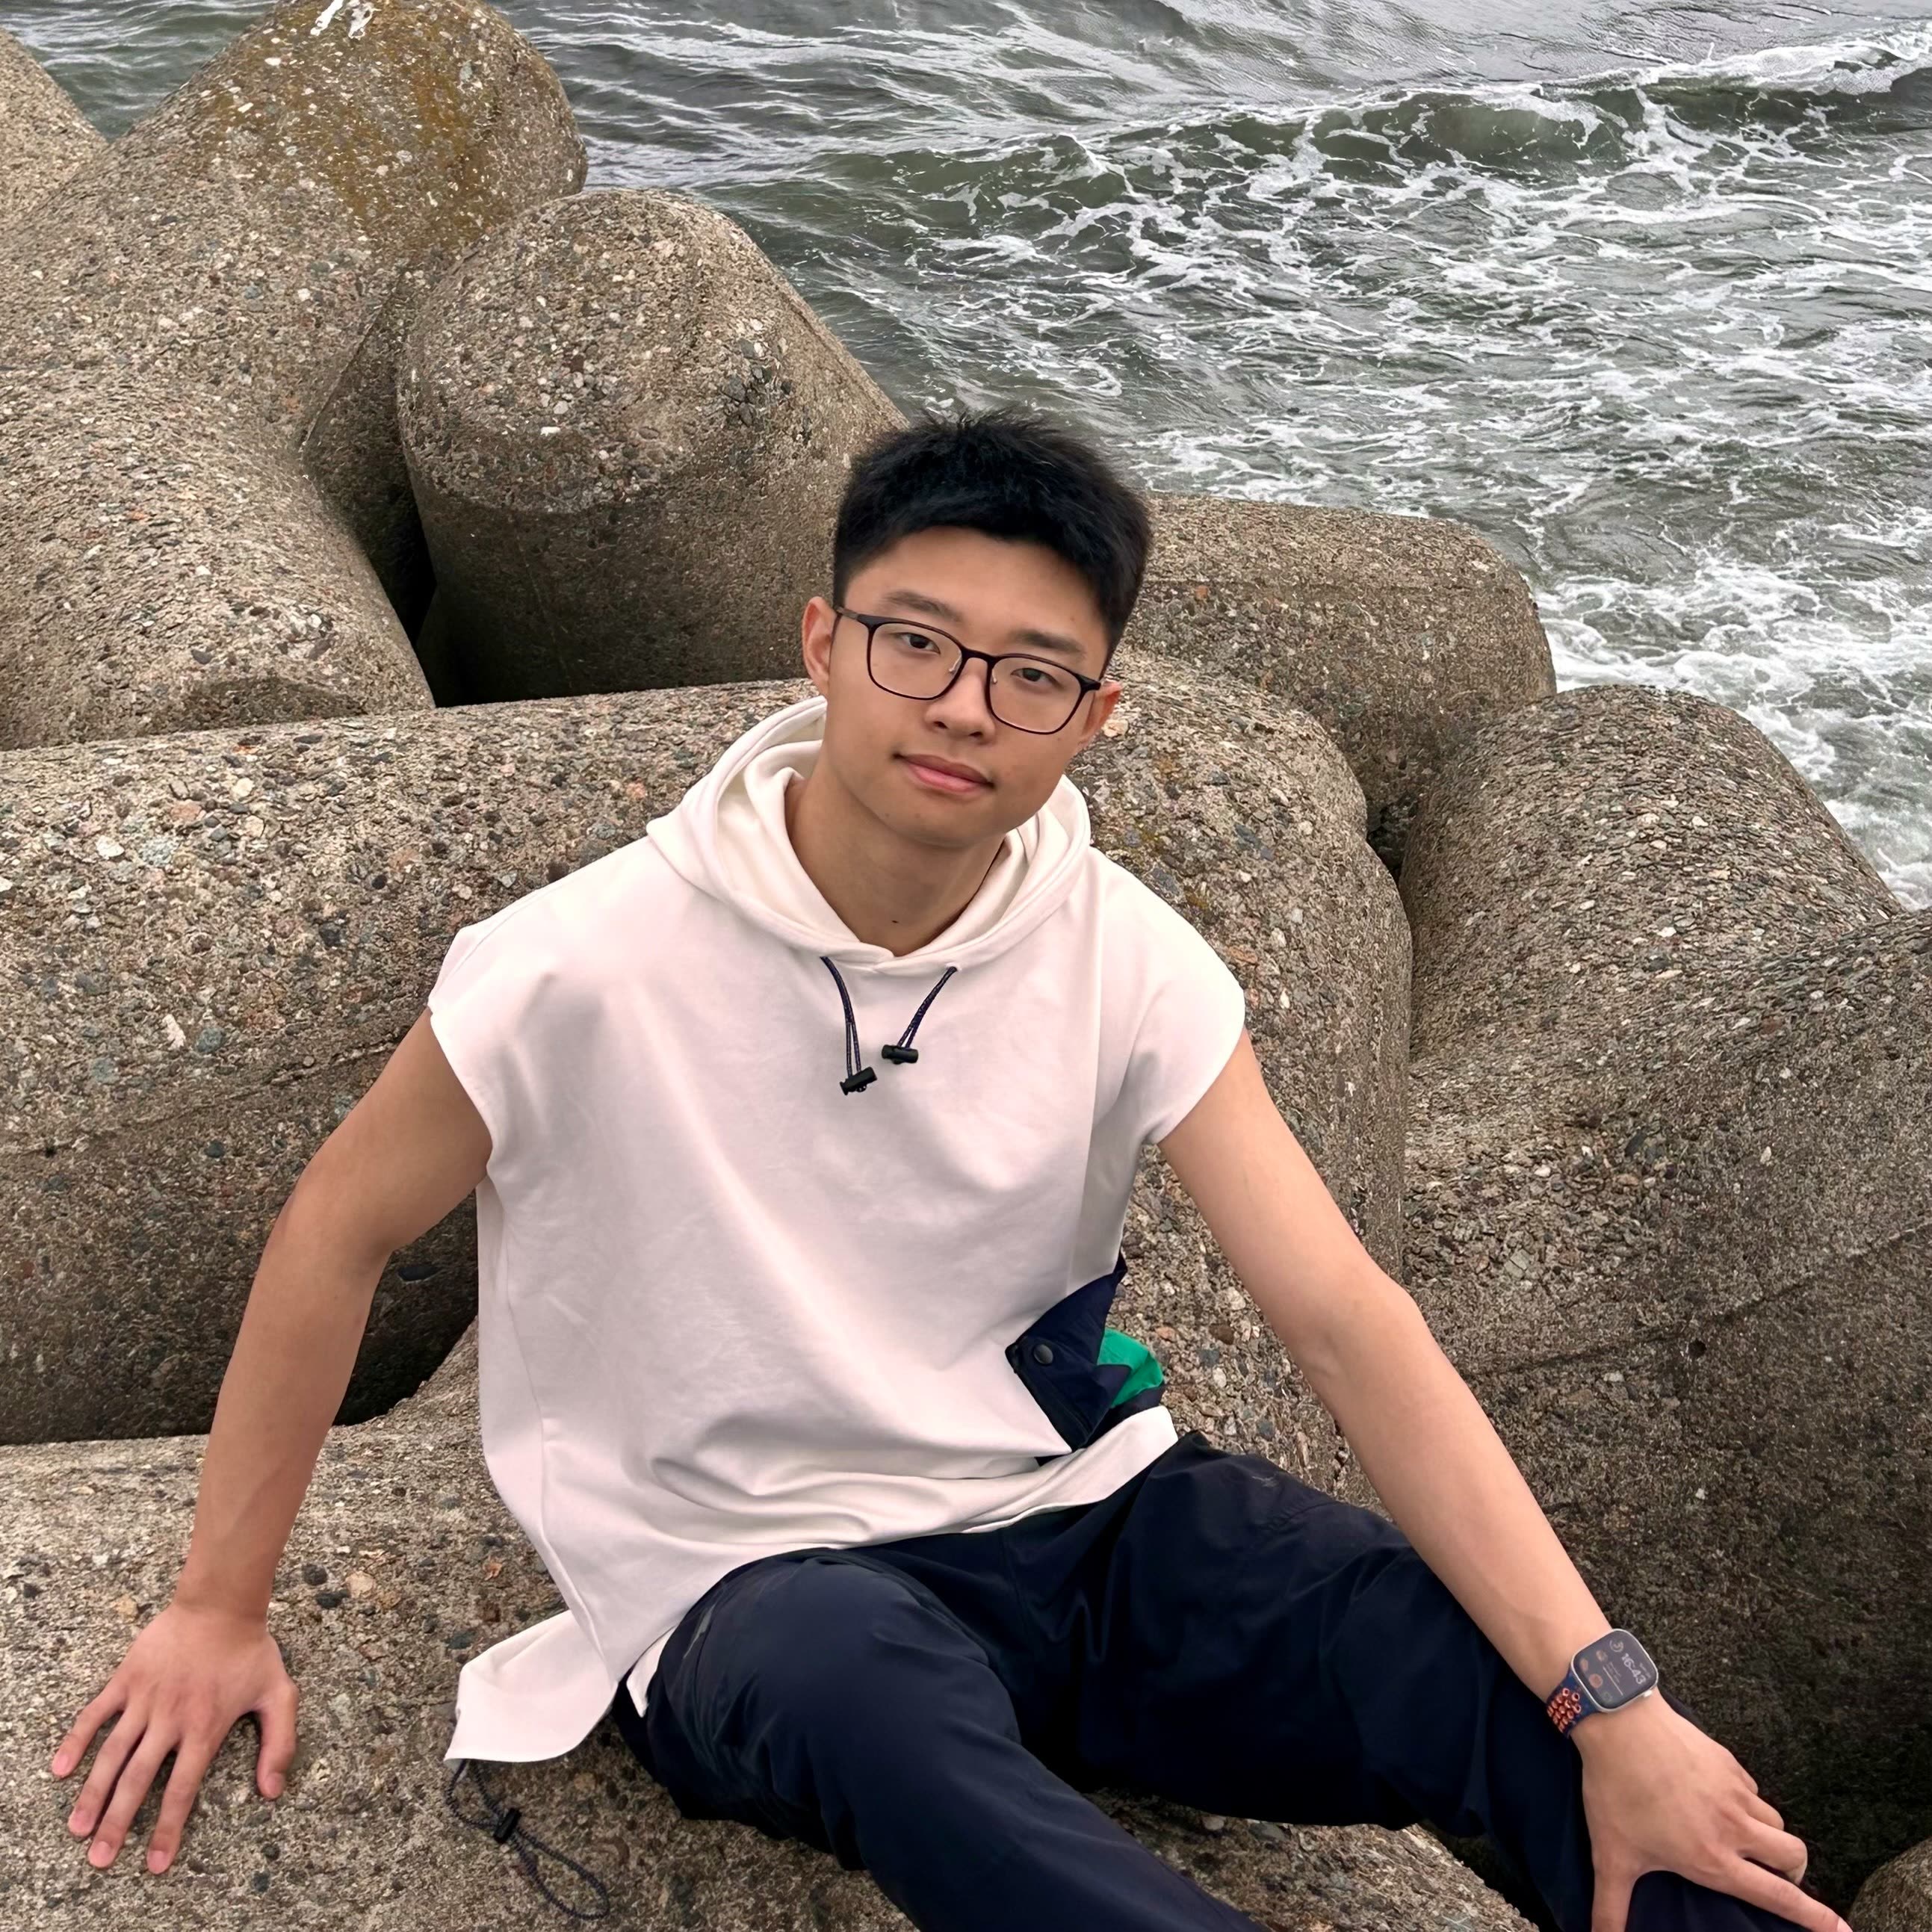
About Me
I am a Ph.D. candidate in Robotics at the University of Michigan, Ann Arbor, working with Prof. Steven Ceron on learning and control for swarm robotics and multi-robot systems. Before that, I received my B.Eng. (Hons) in Aerospace Engineering from the University of Nottingham in 2024, where I began my robotics research with Prof. Erwin (Xin) Dong.
My research interests center on learning and control for intelligent robotic systems, from dexterous manipulation by individual robots to coordinated behavior in large-scale robot collectives. I am particularly interested in reinforcement learning, robot foundation models, and optimization-based control, with the goal of enabling robots to acquire generalizable skills, act reliably in complex environments, and collaborate effectively.
Outside of research, I’m an avid climber and outdoor enthusiast. My personal bests are V10 in bouldering and 5.13a in lead climbing. I also enjoy hiking, long-distance running, and snowboarding.
🔥 News
- 2026.06: One paper, “Nonreciprocal Swarmalators With Reconfigurable and Controllable Formations for Robot Collectives,” was accepted for publication in Advanced Robotics Research.
- 2026.06: I presented two works, “Navigation of Robotic Swarmalators With Dynamics and Constraints” (RA-L) and “3D Robotic Swarmalators That Reconfigure, Navigate, and Avoid Obstacles” (ICRA), at ICRA 2026 in Vienna, Austria.
- 2026.01: One paper, “3D Robotic Swarmalators That Reconfigure, Navigate, and Avoid Obstacles,” was accepted to ICRA 2026.
- 2025.12: I passed my qualifying exam and advanced to Ph.D. candidacy.
- 2025.10: One paper, “Navigation of Robotic Swarmalators With Dynamics and Constraints,” was accepted for publication in IEEE Robotics and Automation Letters (RA-L).
- 2025.04: I transferred to the Ph.D. program in Robotics at the University of Michigan, working with Prof. Steven Ceron.
- 2024.08: 🎉 I’m heading to the University of Michigan to pursue my master’s degree, and I’m eager to explore more about robotics. Hoping to expand my knowledge and skills in this fascinating area!